GSN Robotics Hardware
PSF Helm Sensor Board v1.3
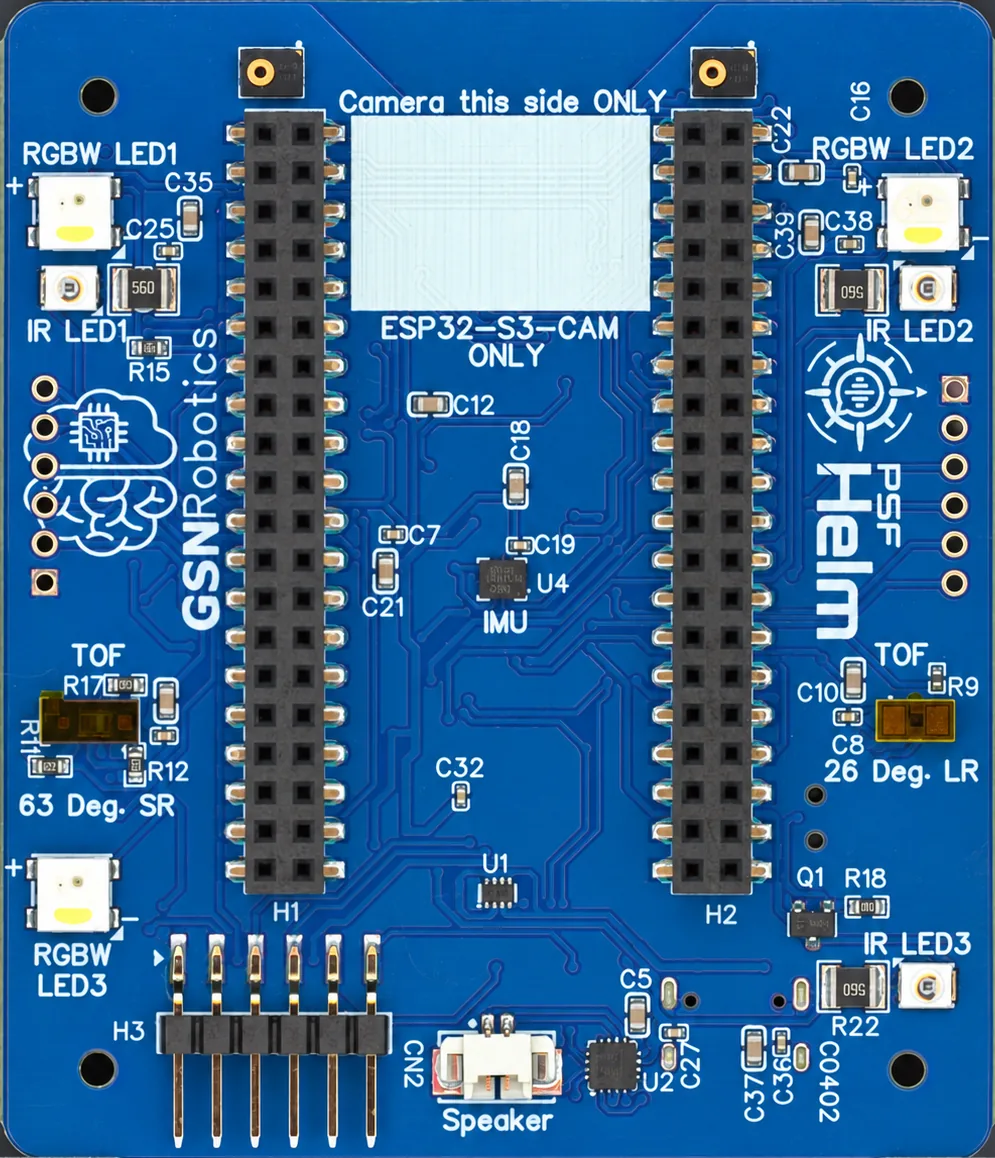
The PSF Helm Sensor Board v1.3 is a compact endpoint sensing platform built for Helm Software. It combines controlled illumination, time-of-flight ranging, required ESP32-S3-CAM visual input, directional audio capture, motion sensing, and flexible power options for workspace awareness and sub-3 ms auto-triangulation workflows.
Sensing stack
Built for short-range precision and workspace coverage.
The board brings multiple local sensing channels into one endpoint module, giving Helm Software the inputs it needs to reason about position, movement, lighting, audio, and proximity around a work area.
Full-spectrum active illumination
Three RGBW LEDs provide controllable full-spectrum color and intensity for active sensing, visual signaling, and environment-aware lighting.
Infrared illumination
Three IR LEDs support close-range sensing workflows and low-visibility illumination strategies designed for precision detection.
Precision positioning support
The illumination and ranging package is designed to support accuracy within 2 mm when used in calibrated Helm deployments.
3 meter ToF array
A front-facing 8 x 8 time-of-flight sensor provides spatial ranging coverage up to 3 meters for near-field awareness.
8 meter ToF channel
A front-facing 1 x 2 x 2 time-of-flight sensor extends ranging capability up to 8 meters for longer workspace reads.
Required ESP32-S3-CAM visual input
The ESP32-S3-CAM is a required part of the board architecture, providing the visual input needed for inspection, operator visibility, and endpoint-local sensing workflows.
Endpoint IO
Audio, motion, output, and power options in one board.
The PSF Helm Sensor Board v1.3 is designed to work as a compact endpoint module, whether it is mounted around a workspace, paired with an Arduino UNO, or powered independently.
- AudioDual-microphone directional audio capture with ambient noise rejection for clearer local audio input.
- Motion6-axis IMU for orientation, movement, and local state awareness.
- OutputSpeaker output for local tones, alerts, voice prompts, or endpoint feedback.
- Optional UNO powerCan optionally be powered from an Arduino UNO through a JST connector for compatible embedded integrations.
- Optional UNO dataCan optionally communicate with an Arduino UNO over UART when a deployment calls for that integration path.
- Primary power optionsCan be powered from a USB-C power supply or battery pack for mobile and distributed placement.
With Helm Software
Auto-triangulation for moving or distributed endpoints.
When multiple PSF Helm Sensor Boards are placed around a workspace or moved through it, Helm Software can combine board telemetry for sub-3 ms auto-triangulation, enabling responsive local positioning and endpoint reflex behavior.
Distribute boards
Boards can be positioned around equipment, work cells, benches, robots, or mobile test areas.
Read the workspace
ToF, illumination, camera, audio, and motion inputs provide a richer local picture for Helm.
Resolve position quickly
Helm Software uses the board network for sub-3 ms auto-triangulation in calibrated deployments.
Act locally
The hardware and Helm endpoint layer can support rapid awareness, feedback, and reflex workflows.
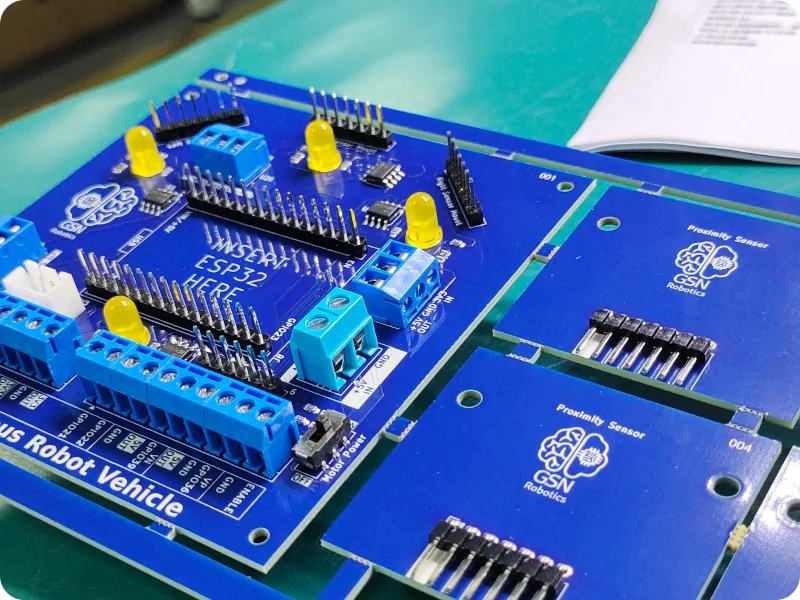
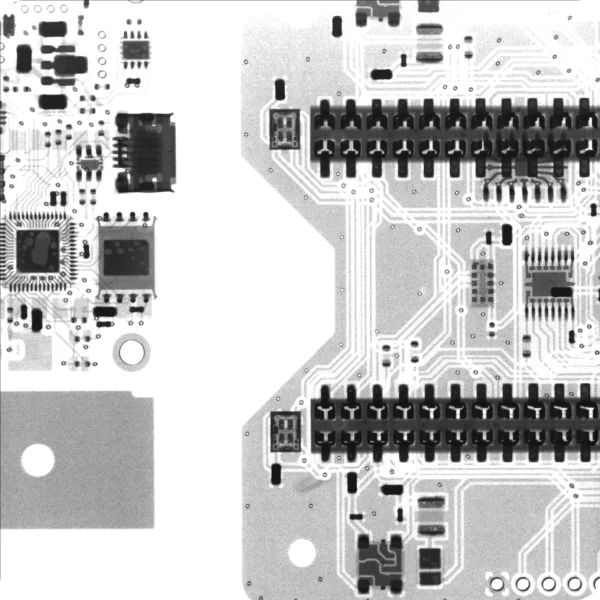
Board views
Designed for real-world endpoint placement.
The board is part of the GSN Robotics hardware layer for PSF Helm, intended to support compact sensing deployments around industrial workspaces, robotics benches, and embedded test environments.
Bring Helm sensing into the workspace.
Contact GSN Robotics about PSF Helm Sensor Board v1.3 deployments, Arduino UNO integration, Helm Software auto-triangulation, and endpoint reflexing.